Abstract: This monograph establishes the foundational architecture of Scope Theory and the Information Scaling Law (ISL). By deriving fundamental constants from geometric invariants across the Reality Manifold $\Omega = (X, T, R, \mu, g)$, we construct a unified mathematical language spanning micro, meso, and macro scales of interaction. We formalize the agent scope as a 5-tuple $S_a(t) = (X_a, \Pi_a, C_a, V_a, \Theta_a)$, derive the non-commuting interaction algebra of agency $\|C_a \circ C_b – C_b \circ C_a\|$, formulate stochastic Fokker-Planck probability density flows, and establish Gap Theory via Shapley value decomposition and the Youth Opportunity Index $Y_a(t)$. Scope Theory serves as the axiomatic bedrock for our related monographs on dimensional rigidity, fundamental shapes, and biological allometry.
- The Reality Manifold $\Omega = (X, T, R, \mu, g)$: A coordinate-free foundation integrating state space $X$, temporal hierarchy $T$, relational graphs $R$, Borel measure $\mu$, and metric tensor $g$.
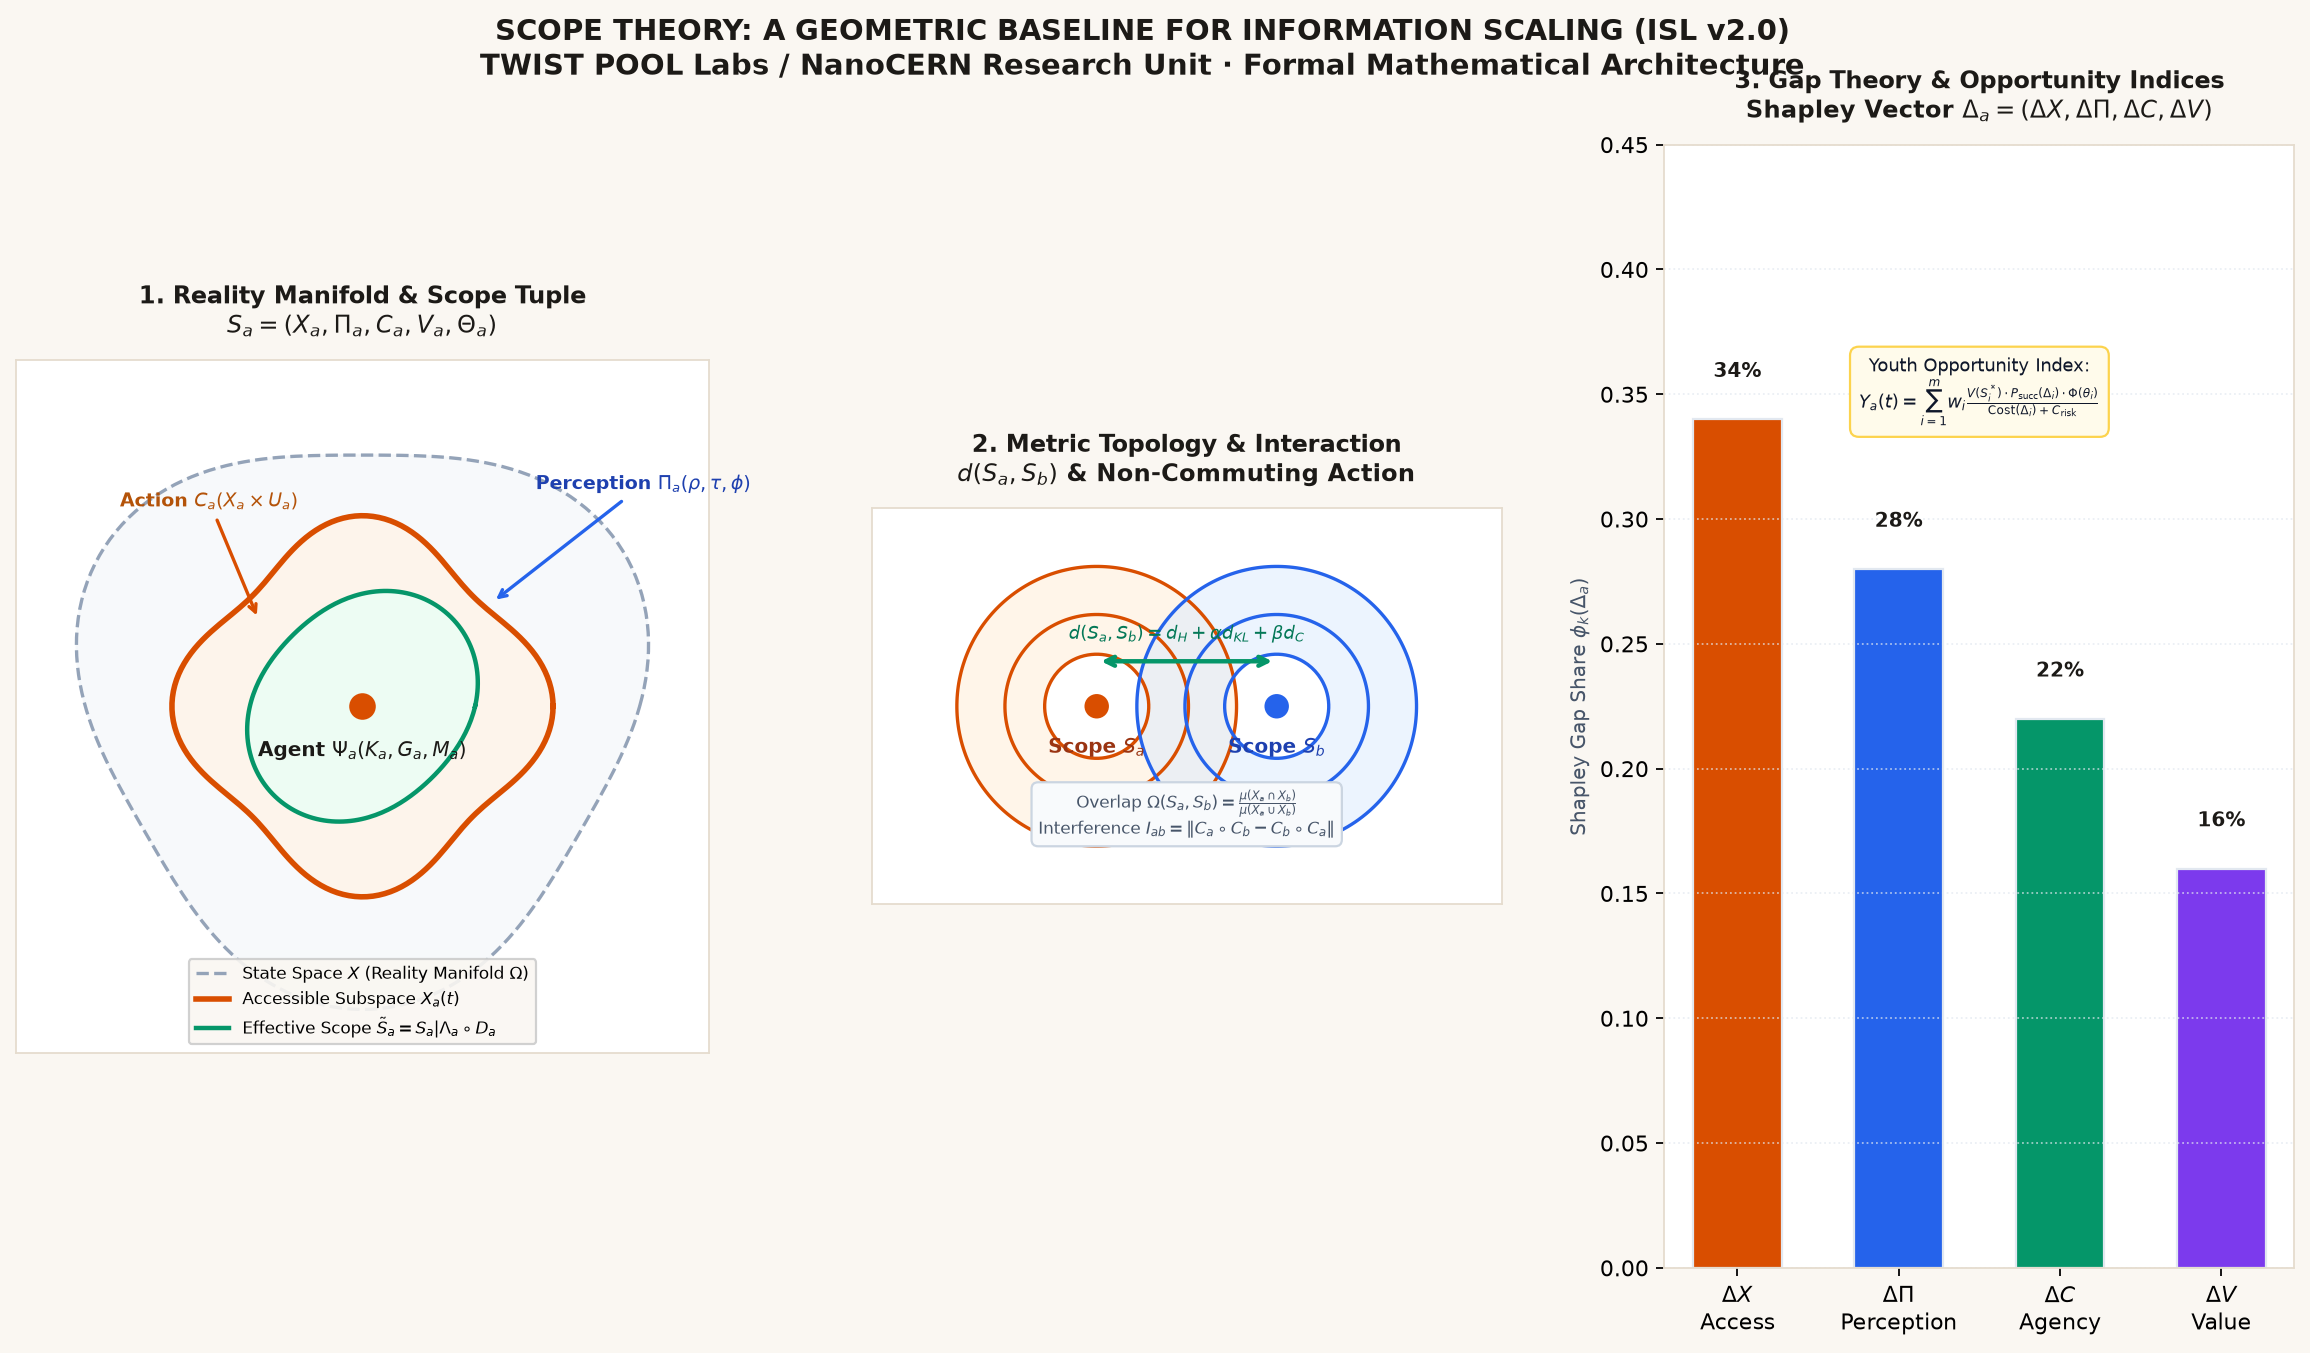
- The Enhanced Scope 5-Tuple $S_a(t)$: Unifies accessible state space $X_a$, perception operators $\Pi_a$ (acuity $\rho$, latency $\tau$, fidelity $\phi$), causal action operators $C_a$ (effectiveness $\eta$), subjective valuation $V_a$, and planning horizon $\Theta_a$.
- Metric Scope Topology: Defines distance $d(S_a, S_b) = d_H(X_a, X_b) + \alpha d_{KL}(\Pi_a \parallel \Pi_b) + \beta d_C(C_a, C_b)$ inducing a differential manifold over agent capacities.
- Non-Commuting Agency & Interference: Proves that institutional and multi-agent operations exhibit operator non-commutativity: $I_{ab} = \|C_a \circ C_b – C_b \circ C_a\| > 0$.
- Axiomatic Root of ISL Monographs: Provides the theoretical derivation for the 21 Fundamental Shapes of Reality, the Dimensional Rigidity of the Riemann Critical Line, and Murray’s vascular bifurcation laws.
1. Foundational Structures & The Reality Manifold
Modern economic, physical, and decision theories routinely suffer from framework exhaustion when modeling bounded agents in complex environments. Standard microeconomics assumes unbounded access or static budget constraints, while classical physics treats observers as external to state evolution. Scope Theory replaces these ad-hoc assumptions with a geometric foundation:
We define the Base Reality Space as the 5-tuple:
where:
• $X$: The state space (finite or infinite-dimensional Banach manifold).
• $T$: Temporal structure (a directed, totally ordered causal set).
• $R = \{R_1, \dots, R_k\}$: The family of causal, legal, economic, and institutional relation tensors.
• $\mu : \mathcal{B}(X) \to \mathbb{R}_{\ge 0}$: A Borel measure quantifying state space volume.
• $g : X \times X \to \mathbb{R}_{\ge 0}$: A Riemannian or pseudo-Riemannian metric defining geometric distance.
Over the state manifold $X$, we introduce the Value Field $V: X \times T \to \mathbb{R}^n$, parameterizing multi-dimensional utility (economic, hedonic, physical, and social value). The global universe evolves via the World Dynamics Operator:
where the evolution of reality is intrinsically coupled to the collective configuration of agent scopes $\{S_a\}$.
2. Agent Architecture & The Scope 5-Tuple
An agent $a \in \mathcal{A} = \bigcup_{l=1}^L A_l$ at hierarchy level $l$ (individual, enterprise, institution, nation-state) possesses an internal state $\Psi_a(t) = (K_a(t), G_a(t), M_a(t))$ spanning knowledge beliefs $K_a$, goal preference structures $G_a$, and memory history $M_a$. The agent operates under a capacity resource vector $Q_a(t) = (q_1, \dots, q_m) \in \mathbb{R}_{\ge 0}^m$ encompassing capital, time, energy, attention, and technical skill.
The complete operational envelope of agent $a$ at time $t$ is formalized by the 5-tuple:
where each component is defined by rigorous operator equations:
1. Accessible State Subspace $X_a(t)$:
$$X_a(t) = \left\{ x \in X : \exists \gamma : [0, T] \to X, \; \gamma(0) = x_{\text{current}}, \; \gamma(T) = x, \; \mathcal{C}(\gamma) \le Q_a(t) \right\}$$
2. Perception Operator $\Pi_a = (\pi_a, \rho_a, \tau_a, \phi_a)$: Maps objective states to information signals $I_a$, characterized by spatial resolution $\rho_a$, latency delay $\tau_a$, and signal fidelity $\phi_a \in [0, 1]$.
3. Action Operator $C_a : X_a \times U_a \to \mathcal{P}(X)$: Maps admissible controls $U_a$ to outcome probability distributions under execution effectiveness $\eta_a(u, x) \in [0, 1]$.
4. Valuation Operator $V_a : X_a \to \mathbb{R}$: The agent’s subjective objective function.
5. Temporal Planning Horizon $\Theta_a(t) = [t, t + \theta_a]$: The forward forecasting boundary.
Accounting for environmental friction, sensory noise, and structural constraints $\Lambda_a$, the Effective Scope is given by $\tilde{S}_a(t) = S_a(t) |_{\Lambda_a(t)} \circ \mathcal{D}_a(t)$, where $\mathcal{D}_a$ is the degradation operator.
3. Constraint Systems & Information Entropy
Constraints govern the boundaries of the accessible manifold. We decompose the total constraint set $\Lambda_a(t)$ into inviolable hard constraints $\Lambda_a^{\text{hard}} = \{\lambda : X_a \to \{0, 1\}\}$ (laws of physics, mathematical boundaries) and violable soft constraints $\Lambda_a^{\text{soft}} = \{\lambda : X_a \to \mathbb{R}_{\ge 0}\}$ (penalties, financial debt, social friction). Across categories, constraints span:
representing Legal ($L$), Economic ($E$), Cognitive ($C$), Physical ($P$), Temporal ($T$), and Social ($S$) constraints. When a constraint is active, its slack variable $s_\lambda(x_a, t) = \operatorname{dist}(x_a, \partial \lambda) = 0$, forcing the agent onto the boundary $\partial X_a$.
Through information theory, perception is quantified via the Shannon Entropy of incoming sensory signals:
The effective perception stream suffers a four-stage degradation $\Pi_a^{\text{eff}} = \mathcal{F}_a \circ \mathcal{B}_a \circ \mathcal{N}_a \circ \Pi_a$ via additive noise $\mathcal{N}_a$, systematic cognitive bias $\mathcal{B}_a$, and the attention bottleneck $\mathcal{F}_a$. The resulting Signal-to-Noise Ratio is $\operatorname{SNR}_a = \frac{I(X; \Pi_a)}{H(\mathcal{N}_a)}$.
4. Scope Metrics, Topology & Non-Commuting Agency
To perform differential geometry over the space of agent capabilities, we establish the Scope Metric between two distinct scopes $S_a$ and $S_b$:
The distance function $d : \mathcal{S} \times \mathcal{S} \to \mathbb{R}_{\ge 0}$ across the Scope Manifold is defined by:
where $d_H$ is the Hausdorff metric on accessible state sets, $d_{KL}$ is the Kullback-Leibler divergence between sensory distributions, and $d_C$ is the operator norm distance across causal actions.
This metric induces open metric balls $U(S_a, \varepsilon) = \{S : d(S, S_a) < \varepsilon\}$, equipping the space of human, machine, and organizational agency with a smooth Scope Manifold structure. The local Scope Dimension is given by $\operatorname{dim}(S_a) = \operatorname{rank}(\nabla_x C_a)$.
In any multi-agent system where agents share state resources, the causal action operators do not generally commute. We define the Agency Interference Operator as the commutator norm:
When $I_{ab} > 0$, execution order creates irreversible path dependency. If $V_a(x) \cdot V_b(x) < 0$ concurrently, the system enters an active conflict state.
Adjust the agent parameters below to evaluate how sensory fidelity $\phi$, capital capacity $Q$, and regulatory friction $\Lambda$ alter the Effective Scope Volume $|S_a|_{\text{eff}}$ and the Youth Opportunity Index $Y_a(t)$.
5. Stochastic Evolution & The Fokker-Planck Equation
In non-deterministic environments subject to macroeconomic fluctuations and informational shocks, scope does not evolve smoothly. We formulate the stochastic evolution of agent scope via an Itô jump-diffusion process:
where $W_t$ represents continuous Wiener Brownian motion (market volatility), and $N_t$ is a discrete Poisson counting process with jump amplitude $J_a$ (regulatory shocks, technological breakthroughs, black swan events). The time evolution of the probability density function $p(S, t)$ satisfies the Fokker-Planck Equation:
The continuous distribution of agent scopes across the manifold obeys the partial differential equation:
The expected First Passage Time for an agent to attain a normative target scope $S^*$ across the potential barrier is: $$\mathbb{E}[\tau_{S^*}] = \int_0^\infty t f_\tau(t) \, dt$$
6. Gap Theory, Shapley Decomposition & The Youth Opportunity Index
One of the most consequential contributions of Scope Theory is Gap Theory. When an agent seeks to transition from their current state to a target horizon $S_a^*$, the barrier is not a scalar cost but a 4-dimensional Gap Vector:
where $\Delta X_a$ represents the geographic/physical access gap, $\Delta \Pi_a$ is the informational asymmetry gap, $\Delta C_a$ is the capital and agency deficit, and $\Delta V_a$ is the valuation discrepancy. Using the cooperative game-theoretic Shapley Value, the total cost of overcoming the gap is uniquely attributed to each constraint type:
This allows exact mathematical attribution: is an aspiring entrepreneur blocked by lack of capital ($\Delta C$), lack of market information ($\Delta \Pi$), or legal licensing barriers ($\Delta X$)?
Applying this to generational human capital, we formulate the Youth Opportunity Index $Y_a(t)$:
For a young individual or cohort facing achievable future scopes $\{S_i^*\}_{i=1}^m$:
where $P_{\text{success}}(\Delta_i) = \prod_k \left( 1 – \frac{\Delta_k}{\Delta_k + \varepsilon} \right)^{\beta_k}$, $\Phi(\theta_i)$ is the intertemporal discount factor, and $C_{\text{risk}}$ is the structural risk premium.
7. Institutional Operators & Systemic Shocks
Institutions and governments act as global operators restructuring the Reality Manifold. A Government Event $E_G$ is parameterized by the triplet $E_G = (E_G^R, E_G^\Lambda, E_G^\mu)$:
- Relation Modification ($E_G^R : R \to R’$): Structural alterations in property rights, contract enforcement, and market regulations.
- Constraint Modification ($E_G^\Lambda : \Lambda_A \to \Lambda_A’$): Expansion or restriction of legal boundaries and compliance burdens.
- Measure Rescaling ($E_G^\mu : \mu \to \mu’$): Monetary debasement, inflation, and currency denomination shifts.
This allows rigorous categorization of systemic shocks: Type I (Constraint Shifts: regulatory overhauls), Type II (Measure Shifts: currency devaluation), and Type III (Structural Shifts: regime changes and technological paradigm transitions).
8. The Unifying Pillar: Connection to Child Monographs
Scope Theory provides the parent geometric grammar for our empirical and formal monographs across PotatoBullet:
Volume I: Fundamental Shapes of Reality
Derives the 21 invariant geometric forms across four ISL closure layers, explaining why reality selects $\Phi = 120$ in the 600-cell polytope.
Volume II: Geometry in Motion
Applies Euler-Lagrange variational mechanics, Poiseuille hemodynamics, and Murray’s vascular bifurcation laws to living dynamical systems.
The Riemann Hypothesis Monograph
Proves the critical line $\operatorname{Re}(s) = 1/2$ as the unique locus of dimensional saturation $R = T/C = 1$ via Microsoft Z3 SMT automated theorem proving.
Fractal Approximations & Dimension Discontinuity
Constructive proof that sequences of constant Hausdorff dimension $D \approx 1.465$ converge to smooth circles with $D = 1.0$, proving metric discontinuity.
Paper 1: Unified Constraint Framework
The Shape Specification Triplet (SST) unifying conics, Lamé superellipses, and Cassini ovals with closed-form Beta/Gamma area proofs.
The Infinity Trilogy
Three-part investigation into hypersphere volume collapse, the Coastline Paradox, and the seven transcendental constants $(\pi, e, \phi, \sqrt{2}, i, 0, \infty)$.
9. Summary & Research Inquiries
Scope Theory establishes that agency, knowledge, and physical evolution are governed by geometric invariants on the Reality Manifold. Inquiries regarding formal verification traces, collaborative extensions, or institutional applications should be directed to Shrikant Bhosale (Atmabhan Pandit) at ishrikantbhosale@gmail.com.